Problem
An automated-machinery scenario calls for coordinated motion, inspection and operator diagnostics to identify product defects consistently without making the control system difficult to support.
The proposed control architecture treats inspection as part of the machine sequence rather than as an isolated camera result. Motion position, part presence, inspection trigger, result availability and reject action are coordinated with defined timeouts and fault responses. This is intended to avoid using a valid-looking inspection value outside the cycle in which it was created.
Operator information should focus on the next useful action. Vision communication, failed inspection, motion readiness and sequence waiting conditions should be separated so troubleshooting does not begin with generic machine faults. A test plan should cover normal product flow, intentional rejects and unavailable or delayed inspection data; handover requires recorded results and acceptance.
Solution
Coordinate machine states, motion sequences and inspection triggers within the control architecture.
Connect inspection results to clear machine responses and operator information.
Plan tests of normal production, rejected-part handling, faults and restart behaviour before handover.
Review the detailed illustrative work package
Engineering scope
- Control-panel and I/O engineering
- PLC and HMI software development
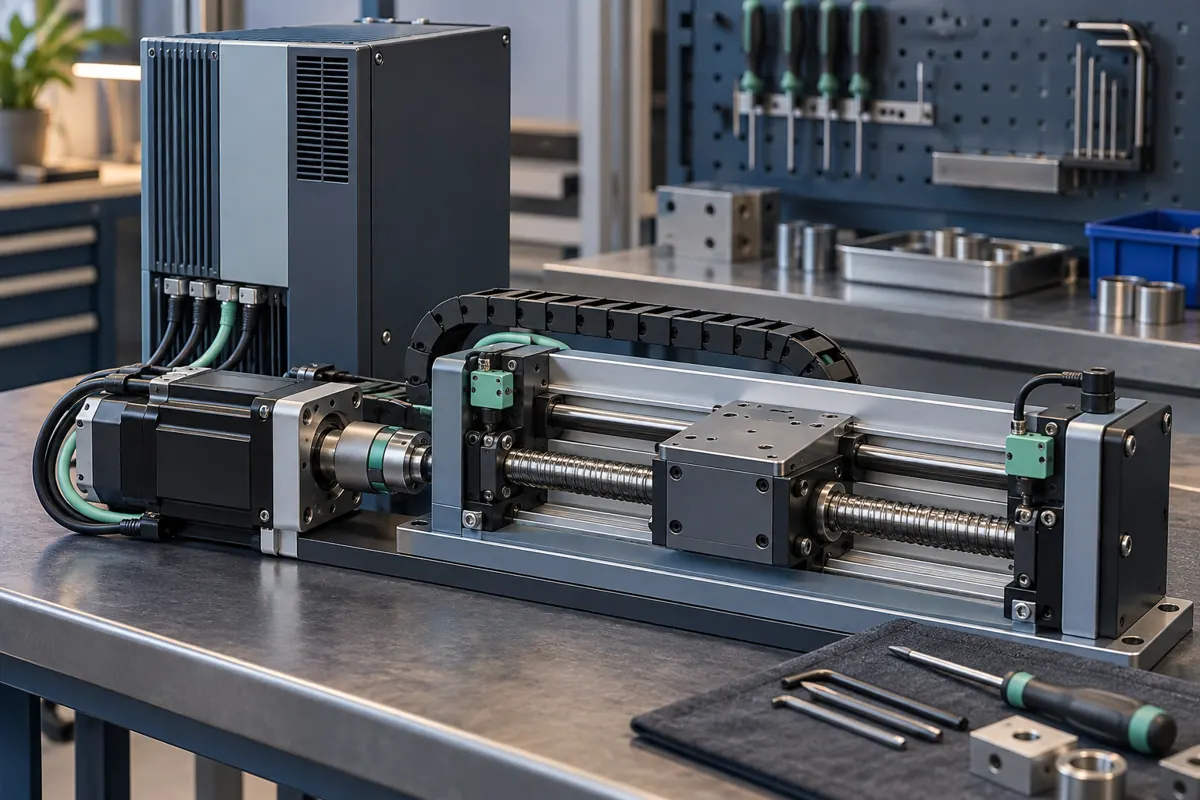
- Beckhoff motion and servo coordination
- Machine-vision inspection integration and commissioning
Inspection integration · Controls work scope
Platforms and equipment interfaces
- Beckhoff TwinCAT
- PLC / HMI
- Servo motion
- Machine vision
Operating constraints
- Inspection timing needs to remain synchronized with motion and machine state.
- Reject decisions need deterministic control responses and useful operator diagnostics.
- The solution needs to remain supportable after commissioning rather than depend on a single developer’s knowledge.
Interfaces
- Beckhoff TwinCAT motion and servo axes
- Machine-vision inspection system trigger and result exchange
- PLC sequence control and safety-adjacent interlocks
- HMI operator diagnostics distinguishing vision, motion, device and sequence causes
Proposed engineering decisions
Treat inspection as part of the machine sequence rather than an isolated camera result.
Motion position, part presence, trigger and reject action are coordinated with defined timeouts, to prevent use of an inspection value outside the cycle in which it was created.
Give each fault class its own operator message (vision, motion, device, sequence).
Troubleshooting begins at the actual cause instead of a generic machine fault, supporting a focused recovery process.
Document sequence assumptions and recovery paths for maintenance at handover.
The solution stays supportable by the plant's own team rather than depending on a single developer's knowledge.
Verification approach
- Test trigger timing, inspection result exchange, timeout handling and loss of communication.
- Verify accepted-part and rejected-part paths across normal cycles, faults and restart conditions.
- Check that HMI messages distinguished vision, motion, device and sequence causes.
Handover requirements
- Preserve coordinated PLC, HMI, motion and vision configuration records.
- Document key sequence assumptions and recovery paths for maintenance personnel.
- Separate engineering walkthroughs from confidential machine design details.
Result and evidence limits
The intended deliverable is coordinated inspection and automation with clear diagnostics; completed testing and performance are not asserted here.
- The highlighted label describes the illustrative controls work scope, not a measured production gain or service-population figure.
- This is an engineering walkthrough, not evidence of a completed customer project. Agree scope and acceptance evidence for the customer’s own equipment and operating context.
- Client identities, proprietary layouts and confidential operating records are not published.
This engineering walkthrough illustrates a proposed method, not a verified completed-project outcome. Numerical performance and operating-scale claims are not published here until their supporting records, original context and publication permission have been reviewed. Acceptance evidence is required for each actual installation.
Earlier employment and retained technical material are not presented as AranVision contracts. Customer identities and confidential records are withheld.
Have a related operating challenge?
Share the system, problem and next decision.
Discuss your projectNo account needed for an initial enquiry. Do not include passwords or confidential files.